Some tasks will require some autonomous operation to achieve full points.
All operations will have a specified margin for error supplied in the task rubric
Teams must declare when entering autonomous mode for any actions taken autonomously to receive full points.
During autonomous operation, no team member may touch the rover controls or operations computers. After doing so, no actions will be considered autonomous until autonomous operation is stopped and restarted.
This includes any form of input to the controls or operations computers, even if they do not affect the rover’s operation (eg. adjusting antenna steering, switching cameras, or mission planning).
A separate computer not controlling the rover is allowed to be used during autonomous operations for mission planning or similar tasks. This should be identified to the judge in the operations tent before the task begins.
The operators should notify the judge whenever a period of autonomous operation is ending. Otherwise, Autonomy Guideline 3 will be used.
All travel distances (specified in meters) are given as the odometer distance travelled over the actual local terrain, such as would be measured with a flexible tape measure.
For tasks requiring rovers to travel to a waypoint, the waypoint will be provided as GNSS coordinates using the WGS 84 datum in decimal degrees. Coordinates will be provided at the start of the tasks.
For the identification of objects, or interaction with objects, the waypoint or object will be designated using an Aruco machine vision marker.
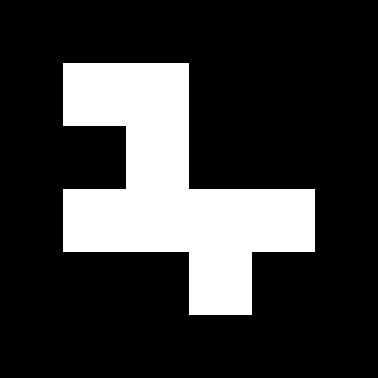
All ArUco markers will be from the 4x4_100 dictionary. They range from marker 0 to 99.
Each marker will be a minimum size of 2” x 2” or 5cm x 5cm.
Markers will be attached to surfaces that contrast the Aruco markers.
For example, Marker 7 looks like the following:
For full points, the Aruco scanning software must run on the rover or base station computer and automatically output the result to a screen that the judge can see.
Manually identifying the markers via a lookup table or other manual methods are not accepted.
For validation that the rover has successfully completed autonomous operations, rovers must be equipped with a CIRC provided indicator package, including a ground reference and orientation reference.
Mechanical drawings will be published by October 30th
The end effector must also have a single reference mark, for measuring height above the ground, and position relative to task elements.
Examples of actions that can be completed autonomously may include, but are not limited to the list below. The exact list will be published in the task rules section.
The list is not in any order, and all tasks will have a margin for error described in the task rubric
Drive forward N meters, where N may be 1, 3, 5, or an identifier from an aruco marker
Drive backwards N meters
Store your arm and end effector to a defined home position
Raise your end effector to its maximum height above the ground
Lower your end effector to its minimum height above the ground
Open your end-effector’s gripper to at least N centimeters, where N will be at most 100mm
Close your end effector around an object, handle, or lever
Release an object you have gripped
Close your end-effector’s gripping mechanism completely
Rotate your rover by N degrees relative to its current orientation
Rotate your rover so it is facing absolute bearing XYZ (50 degrees)
Move your rover N meters in the direction M degrees clockwise from where it’s currently facing
Move your rover N meters in the bearing M, ending at orientation X
Read an Aruco marker in front of the rover and display the identifier to an operator, or remember the identifier for later
Position the end effector horizontally at a specified height above the ground and distance from the front of the rover.
Position the end effector horizontally at a specified height and position relative to the rover position reference
Position the end effector horizontally at a specified height and position relative to an aruco marker
Travel so that your rover’s position reference is within 3m of the waypoint at provided GNSS coordinates.
Travel so that your rover’s position reference is within 1m of the tower labelled with Aruco marker #3, located at approximately these GNSS coordinates.
Push the button located relative to Aruco markers #8 and #9 according to the supplied drawing
Report a GO or NO-GO decision based on a supplied formula and the value of the scanned Aruco marker.
Use the value of the scanned Aruco marker as a code or input for another part of the task.
Pick up a thing from the specified location on the ground, relative to the rover’s position reference or to an aruco marker
Put down a thing at a specified location on or above the ground, relative to the rover’s position reference or to an aruco marker
Deposit a held object into the bin directly underneath Aruco marker #4
Teams may be required to follow additional requirements for the interface(s) that activate autonomous operations, and judges may be the individuals responsible for interacting with the interface(s)
Exact interface requirements will be published with the task descriptions